|
I am currently a research engineer at Xiaomi Autonomous Driving under the Future Star Program, working on world simulators with a focus on feed-forward 3D/4D reconstruction and video world models. I obtained my Ph.D. degree in 2025 from the College of Control Science and Engineering, Zhejiang University, advised by Researcher Jiajun Lv, Prof. Xingxing Zuo, and Prof. Yong Liu. My doctoral dissertation consists of RA-L ×2, ICRA ×1, and IJRR ×1 first-authored papers on LiDAR-Visual-Inertial SLAM and 3D Gaussian Splatting, with all code open-sourced (1.5k stars and 160 forks). Beyond this geometry-based 3D vision research track, I have also actively explored video generation and world(-action) models through internships at Amap, Baidu, and GigaAI. |
|
|
|
|
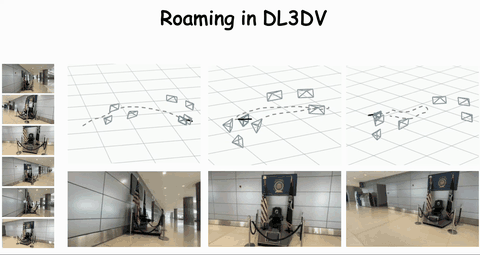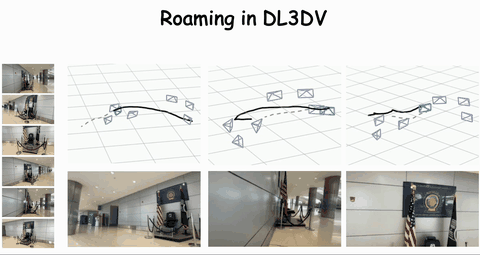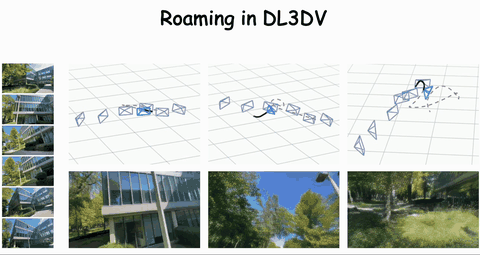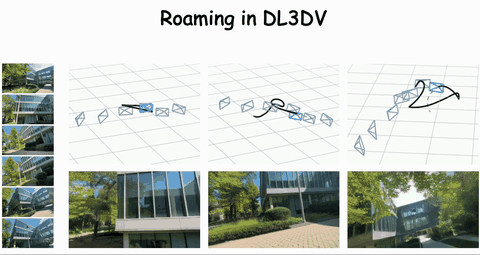
Xiaolei Lang, Ze Kang, Zehao Huang, Naiyan Wang arXiv, 2026 [arXiv] [Code] [Page] We present the first end-to-end unified reconstruction and generation framework for sparse novel view synthesis, where ray-queried implicit geometric features condition video diffusion without an explicit 3D bridge. |
|
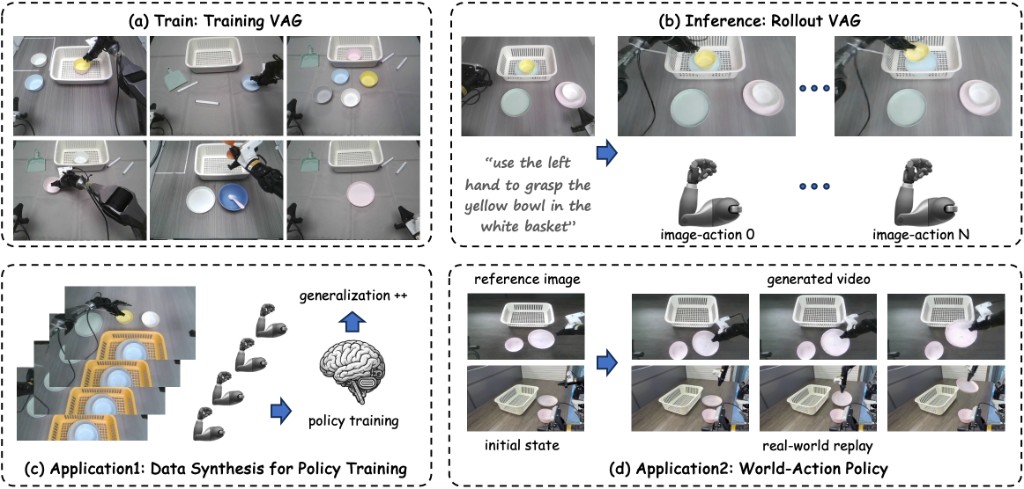
Xiaolei Lang, Yang Wang, Yukun Zhou, Chaojun Ni, Kerui Li, Jiagang Zhu, Tianze Liu, Jiajun Lv, Xingxing Zuo, Yun Ye, Guan Huang, Xiaofeng Wang, Zheng Zhu arXiv, 2026 [arXiv] We propose a dual-stream video-action generation framework that jointly synthesizes visually coherent videos and executable action trajectories for embodied data synthesis. |
|
Xiaolei Lang, Jiajun Lv, Kai Tang, Laijian Li, Jianxin Huang, Lina Liu, Yong Liu, Xingxing Zuo The International Journal of Robotics Research (IJRR), 2026 🔥 [arXiv] [Code] [Video] [Page] We present the first photo-realistic LiDAR-Inertial-Camera Gaussian Splatting SLAM that jointly addresses visual quality, geometric accuracy, and real-time performance. |
|
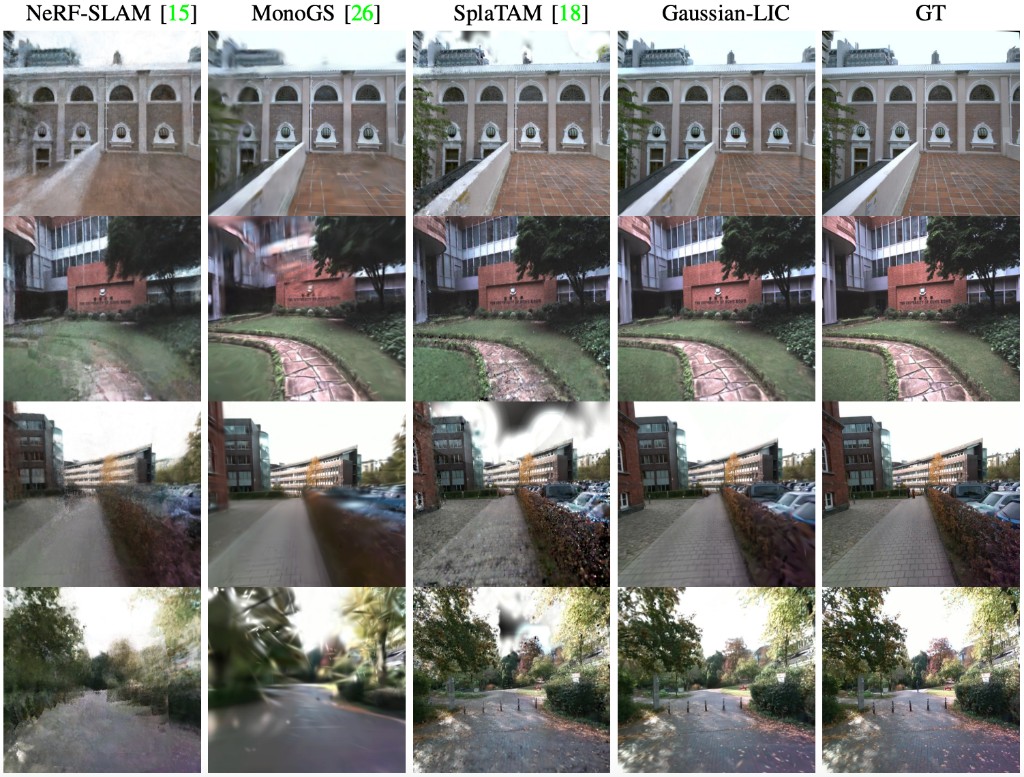
Xiaolei Lang, Laijian Li, Chenming Wu, Chen Zhao, Lina Liu, Yong Liu, Jiajun Lv, Xingxing Zuo IEEE International Conference on Robotics and Automation (ICRA), 2025 🔥 [arXiv] [Code] [Page] We propose a real-time photo-realistic SLAM method that marries Gaussian Splatting with tightly-coupled LiDAR-Inertial-Camera odometry for robust pose estimation and high-quality online mapping. |
|
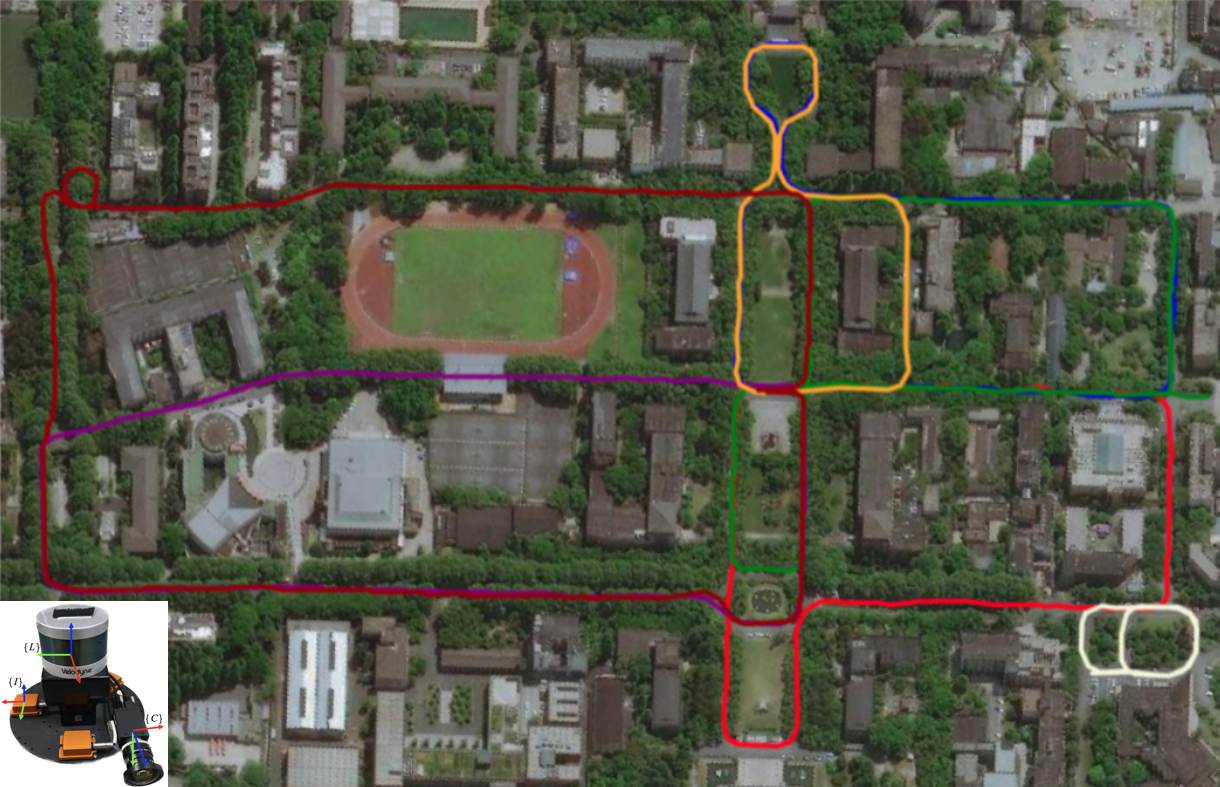
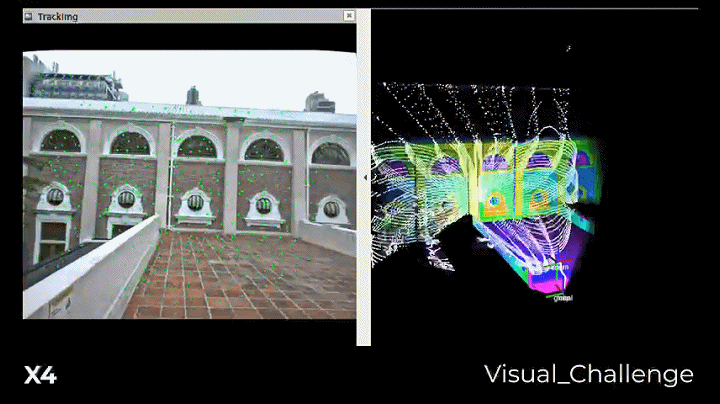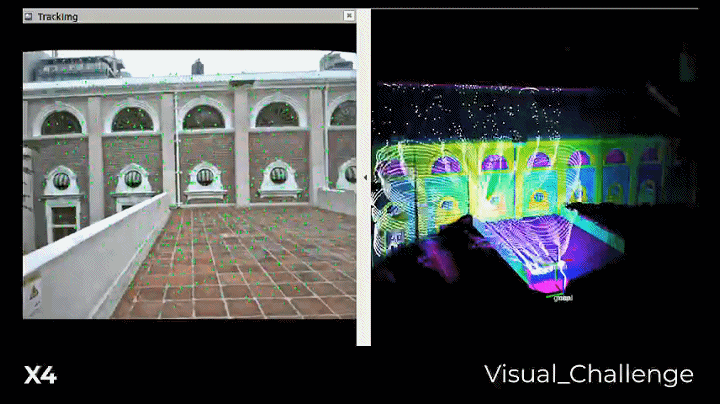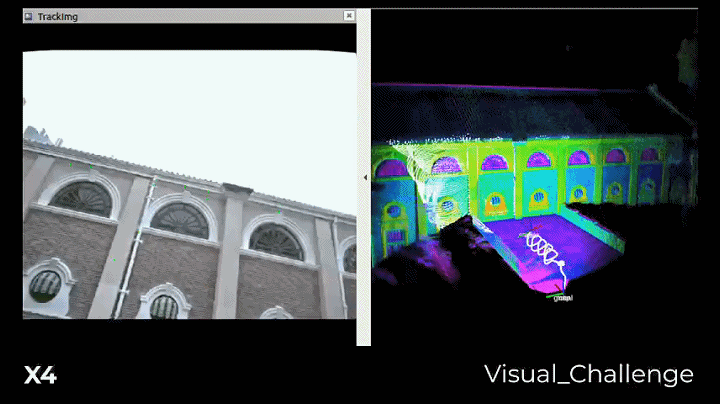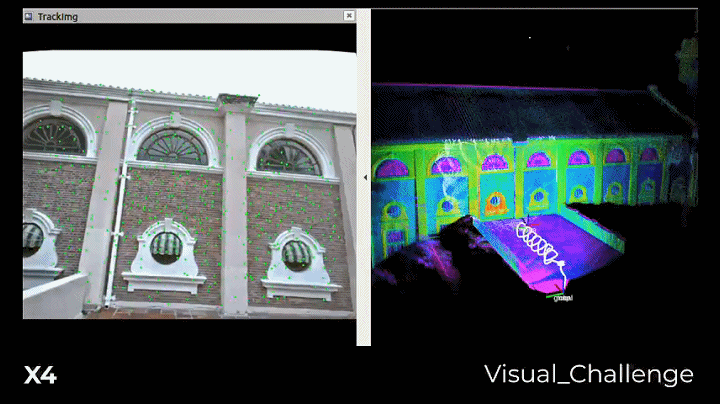
Jiajun Lv, Xiaolei Lang, Jinhong Xu, Mengmeng Wang, Yong Liu, Xingxing Zuo IEEE/ASME Transactions on Mechatronics (T-Mech), 2023 [arXiv] [Code] We estimate continuous-time trajectories by fixed-lag smoothing within a factor-graph framework to fuse asynchronous LiDAR, IMU, and camera measurements for tightly-coupled multi-modal SLAM. |
|
Xiaolei Lang, Chao Chen, Kai Tang, Yukai Ma, Jiajun Lv, Yong Liu, Xingxing Zuo IEEE Robotics and Automation Letters (RA-L), 2023 [arXiv] [Code] [Video] We propose an efficient continuous-time LiDAR-Inertial-Camera odometry with non-uniform B-splines that adaptively place control points according to motion dynamics. |
|
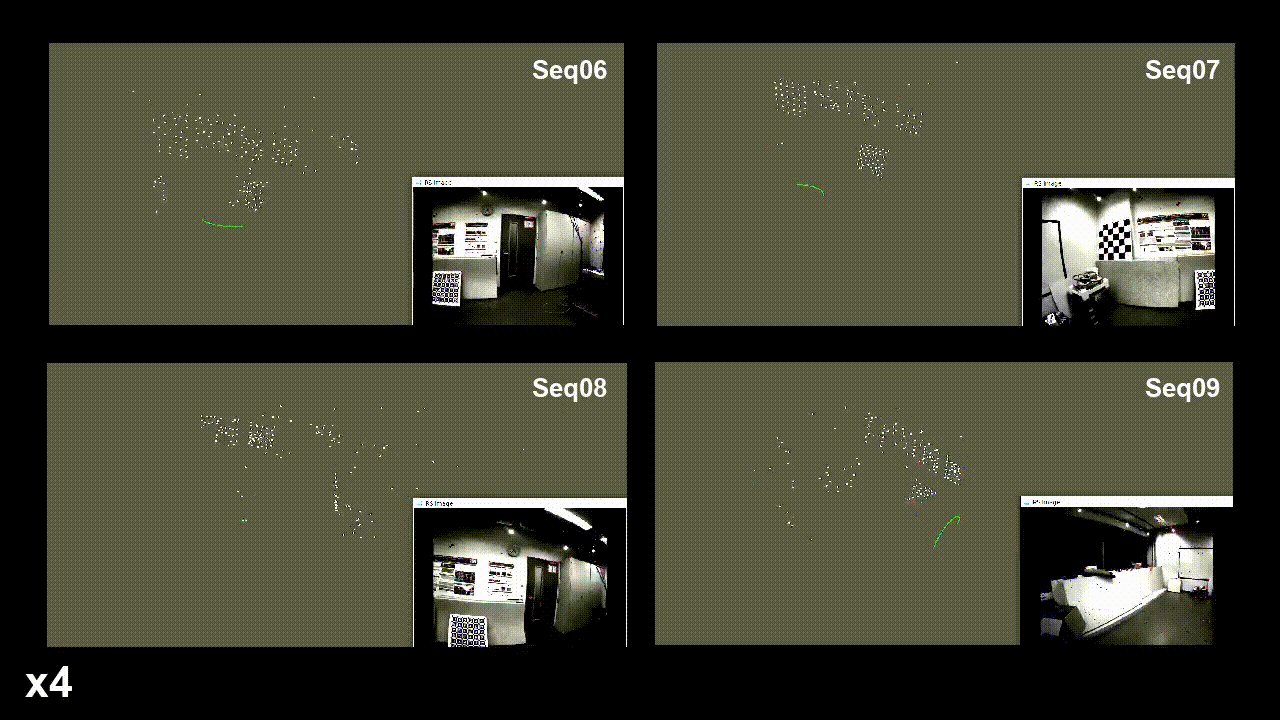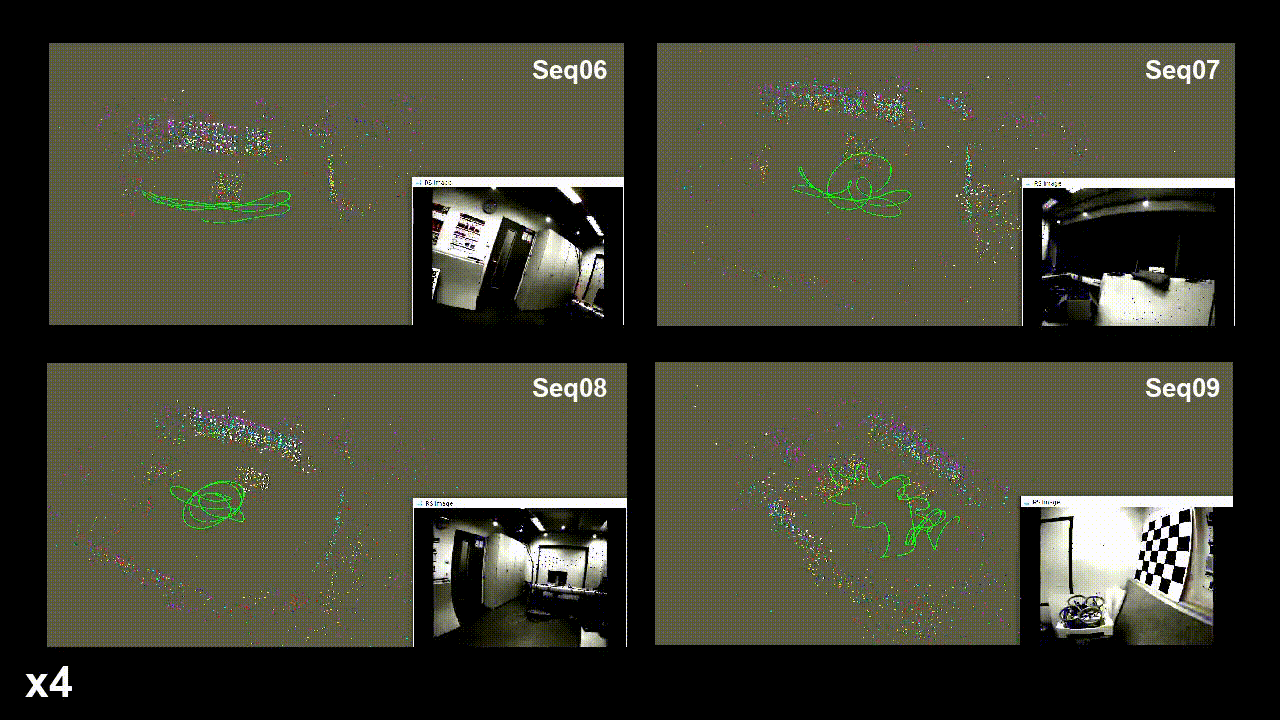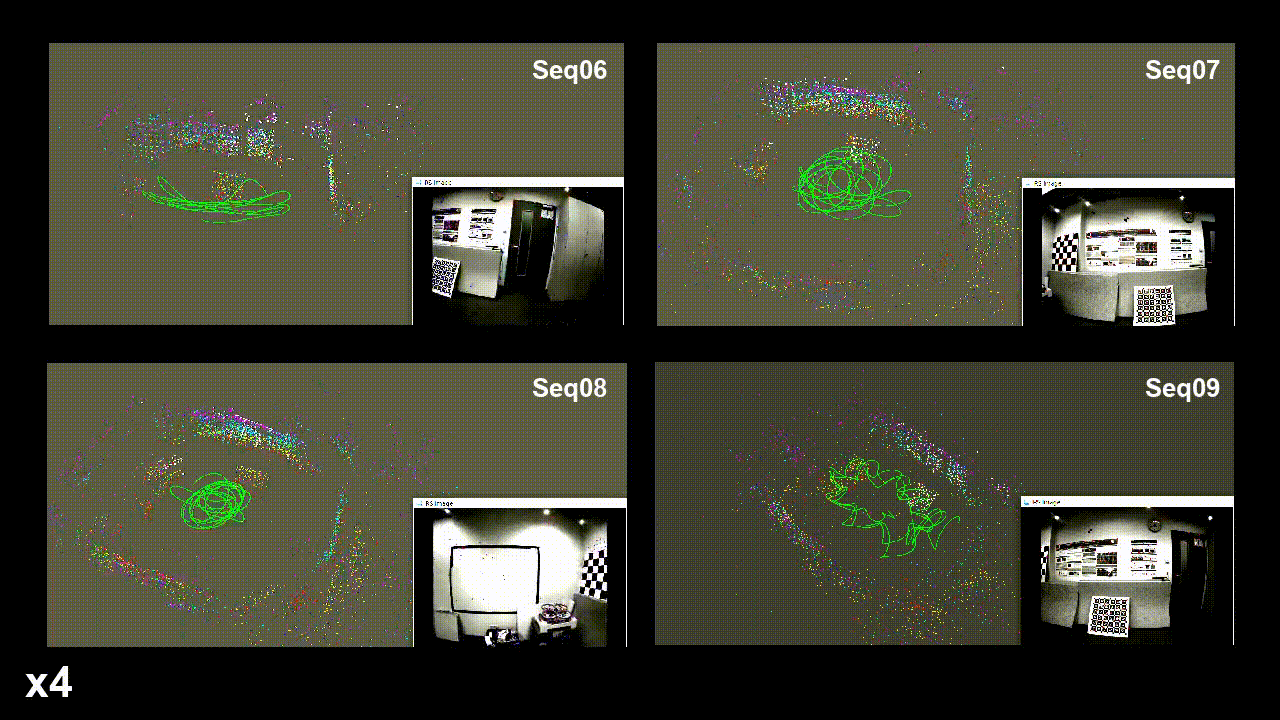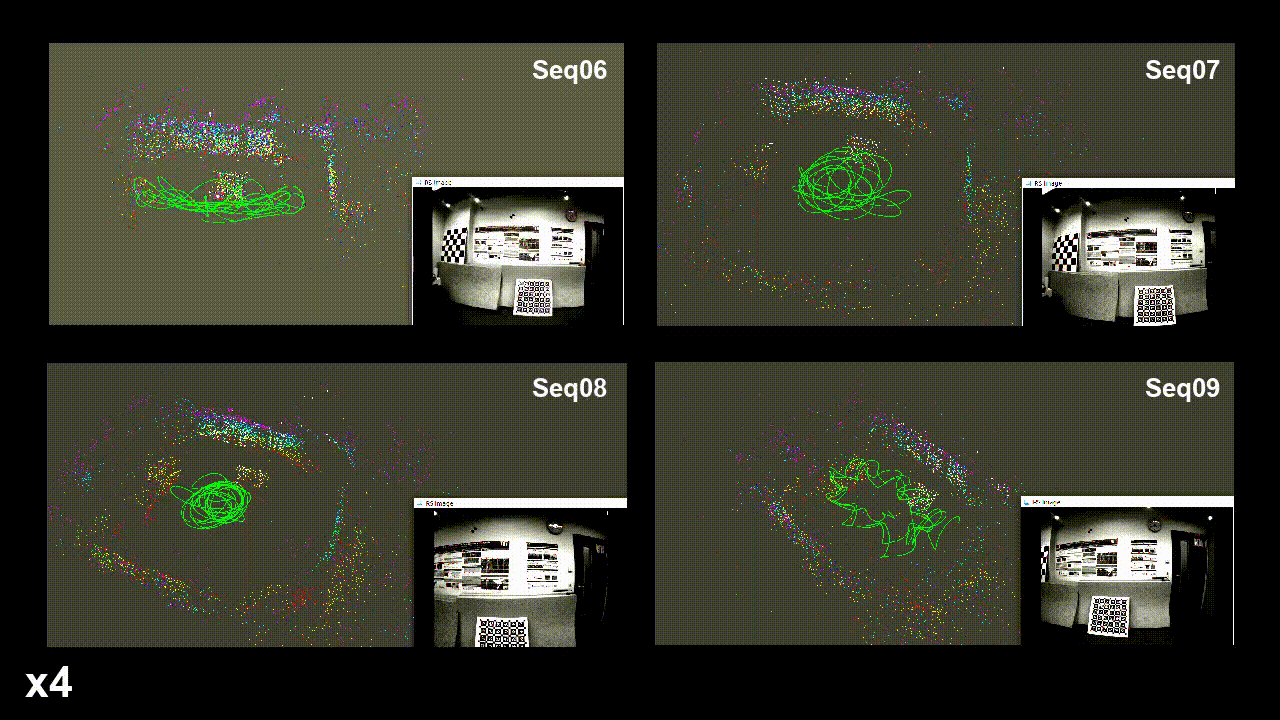
Xiaolei Lang, Jiajun Lv, Jianxin Huang, Yukai Ma, Yong Liu, Xingxing Zuo IEEE Robotics and Automation Letters (RA-L), 2022 [arXiv] [Code] [Video] We propose a probabilistic continuous-time VIO for rolling shutter cameras with B-spline control-point marginalization and online line-delay calibration. |
|
|
|
Research Intern, Embodied AI Research Group, 2025 Topic: [World Model] dual-stream video-action generation |
|
Research Intern, Computer Vision Technology Department, 2024 Topic: [3D AIGC] diffusion-aided 3d digital human reconstruction |
|
Research Intern, Computer Vision Technology Center, 2023 Topic: [3DGS] large-scale reconstruction and on-device rendering |
|
Engineer Intern, Autonomous Driving Mapping and Localization R&D Department, 2022 Topic: [Crowdsourced Mapping] pole mapping based on lidar-visual fusion |
|
University-Enterprise Project, Project Leader, 2023 Topic: [Calibration] roadside mmwave radar–camera extrinsic calibration |
|
University-Enterprise Project, Project Leader, 2021 Topic: [Calibration] uav camera–imu spatial-temporal calibration |
|